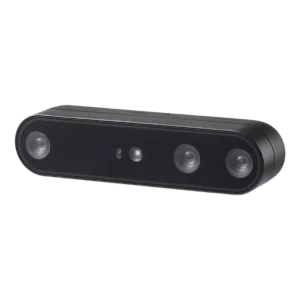

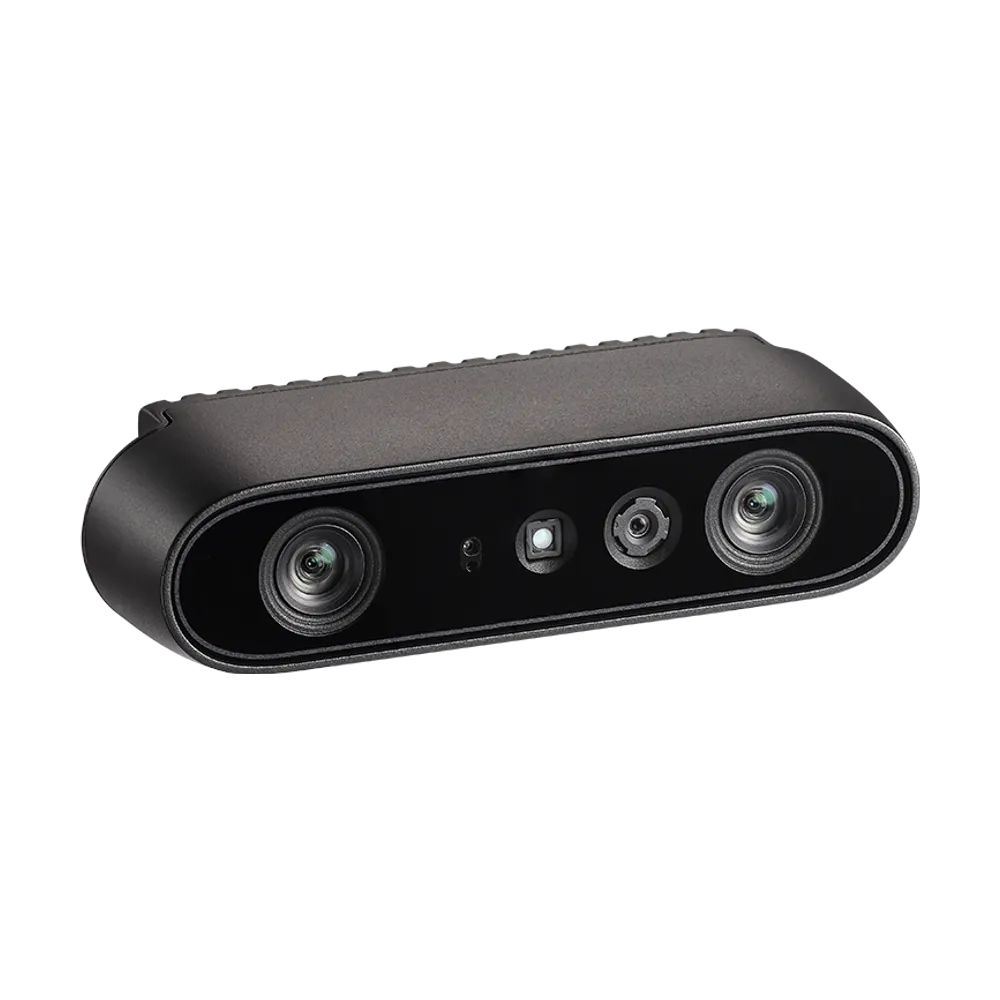
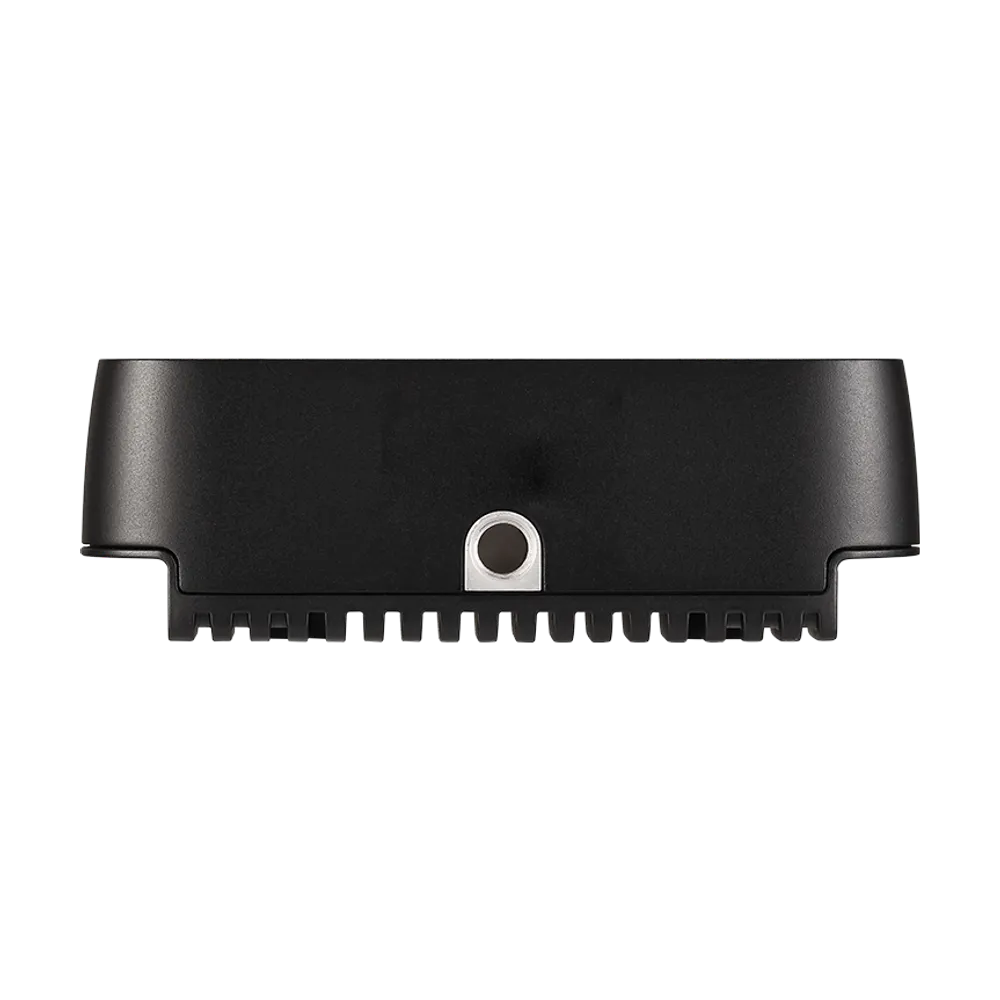


Orbbec Gemini 335 is a stereo depth camera with RGB imaging and a 6-axis IMU. It supports multi-device synchronization and integration via Orbbec SDK.
<trp-post-container data-trp-p...

Looking Glass 16 OLED Landscape


Orbbec Gemini 335
Orbbec Gemini 335 is a stereo depth camera for projects that use spatial imaging. If you are building your own measurement setup or application, you can work with point clouds, depth maps, IR images and RGB images. These different data types help you choose an analysis method for the task at hand. Its compact size means you can account for the device when designing your solution.
Measurement is based on active and passive stereo vision, so you can choose an operating mode to suit the scene conditions. The measurement range is from 0.1 m to over 20 m, with the optimal range for planning the setup being from 0.3 to 3 m. The depth image reaches 1280 × 800 at 30 fps, and the field of view is 90° × 65° at 2 m, with a tolerance of ±3°. Spatial accuracy ≤1,5% helps account for accuracy when analysing distances.

The color image has a resolution of up to 1920 × 1080 at 30 fps. At a 16:9 aspect ratio, its field of view is 86° × 55°, with a tolerance of ±3°. These values let you assess whether the planned frame covers the area of interest before permanently mounting the camera. 6-axis IMU provides additional motion data. This is useful when a project requires linking the observed scene to changes in the device's position during operation.

Processing is handled by Orbbec MX6800 ASIC, and application integration is supported by Orbbec SDK. You can connect the camera via USB 3.0 or USB 2.0 Type-C; power requires DC 5 V and at least 1.5 A through this connector. Average power consumption is less than 3.0 W, and the peak value is below 6.5 W, making it easier to choose a power source. For a setup with multiple cameras 8-pin port, unified hardware timestamps and external trigger support help you plan synchronization.

The camera has 90 × 25 × 30 mm and weighs 97 g, so you can plan the space needed for the device and the load on the mount in advance. Mounting points include 1/4-20 UNC thread on the underside and two M3 holes on the rear. Rating IP5X indicates protection against dust, with no stated water resistance. The operating range is from -10°C to 45°C at 15 fps and from -10°C to 40°C at 30 or 60 fps. The permitted humidity is 5 to 90% RH, non-condensing.
The optimal measurement range is 0.3 to 3 m. The camera supports measurements from 0.1 m to over 20 m, but it is best to start designing the setup around the optimal range.
The camera requires DC 5 V and at least 1.5 A via USB Type-C. When choosing a port or hub, also account for peak power consumption below 6.5 W.
Yes, Gemini 335 supports multi-device synchronization with a unified hardware timestamp. It has an 8-pin synchronization port and supports an external trigger.
Full technical specifications grouped by topic.
 Orbbec Gemini 335
We use cookies to store and access data on your device, including browsing data and identifiers. Without your consent, some features may not work as well.